
Feedback Control Systems
Course facts
- Payment: Free, no certificate
- Credits: Non Credit
- Learning style: Self-paced, start anytime
- Resources: Design Assignments; Lecture Notes; Problem Sets
MIT OpenCourseWare details
- As taught in: Fall 2010
- Department: Aeronautics and Astronautics

| Course Details | ||||||
|---|---|---|---|---|---|---|
|
||||||
| Outcomes | ||||||
|
||||||
| Price & Terms | ||||||
|
||||||
| Technical | ||||||
|
||||||
| Specification | ||||||
|
||||||

Control design using state-space methods: feedback, estimators, LQR and LQG, plus nonlinear analysis, robustness, labs and design homework.
A controller that works on paper can still fail once delay, nonlinearity and modeling errors enter the picture. This course teaches control design and analysis using state-space methods, in both theory and practice. It reviews classical tools, then covers full-state feedback, estimation and output feedback, followed by linearization, stability analysis and the robustness of a design.
What You Will Achieve
- Design controllers using state-space methods and analyze them using classical tools
- Assess the impact of nonlinearity and delay on a design
- Evaluate the robustness of a control design to modeling errors
- Linearize a nonlinear system and analyze its stability
Program Overview
Classical Methods and State-Space Models
Review and the models the course relies on.
- Basic root locus
- Control design using Bode plots
- Transfer function matrices
- Controllability
Full-State Feedback and Estimators
Building controllers and the estimators they need.
- Pole placement approach
- Open-loop and closed-loop estimators
- Adding reference inputs
- LQR and LQG
Digital Control and Nonlinear Systems
Issues that arise when a controller is implemented.
- Digital control basics
- Analysis of nonlinear systems
- Anti-windup
- Closed-loop system analysis
Course Completion
Job Outlook
Control design skills apply to aerospace and other engineering work on dynamic systems and their controllers.
Good for: Engineering students who want a practical, notes-based course on state-space control design with labs and homework.
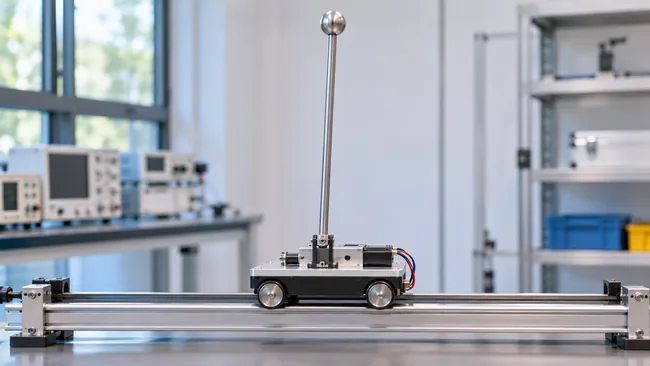
Keep in mind: One project option uses Quanser hardware and LabVIEW, which you may not have, and the work calls for MATLAB and some Simulink. No exams or solutions are listed.
Bottom line: A clear path into modern control design, with self-contained notes and no required textbook.
Frequently Asked Questions
Is a textbook required?
No, lecture notes are provided. Recommended books include Feedback Control of Dynamic Systems by Franklin, Powell and Emami-Naeini, and Feedback Systems by Astrom and Murray.
What do the graduate project options look like?
Options are summarizing two recent papers, designing a controller for a system from your research, implementing a MIMO controller on the Quansers, or an idea of your own.
Are there labs?
Yes, two labs and a competition appear with the seven homework assignments. Group work in the labs was blended in with the homework later in the term.

There are no reviews yet.